

Compact & Lightweight
180 mm long and weighing up to 550 g, with a compact form designed for integration with humanoid robots.
Shop by robot type
Product series

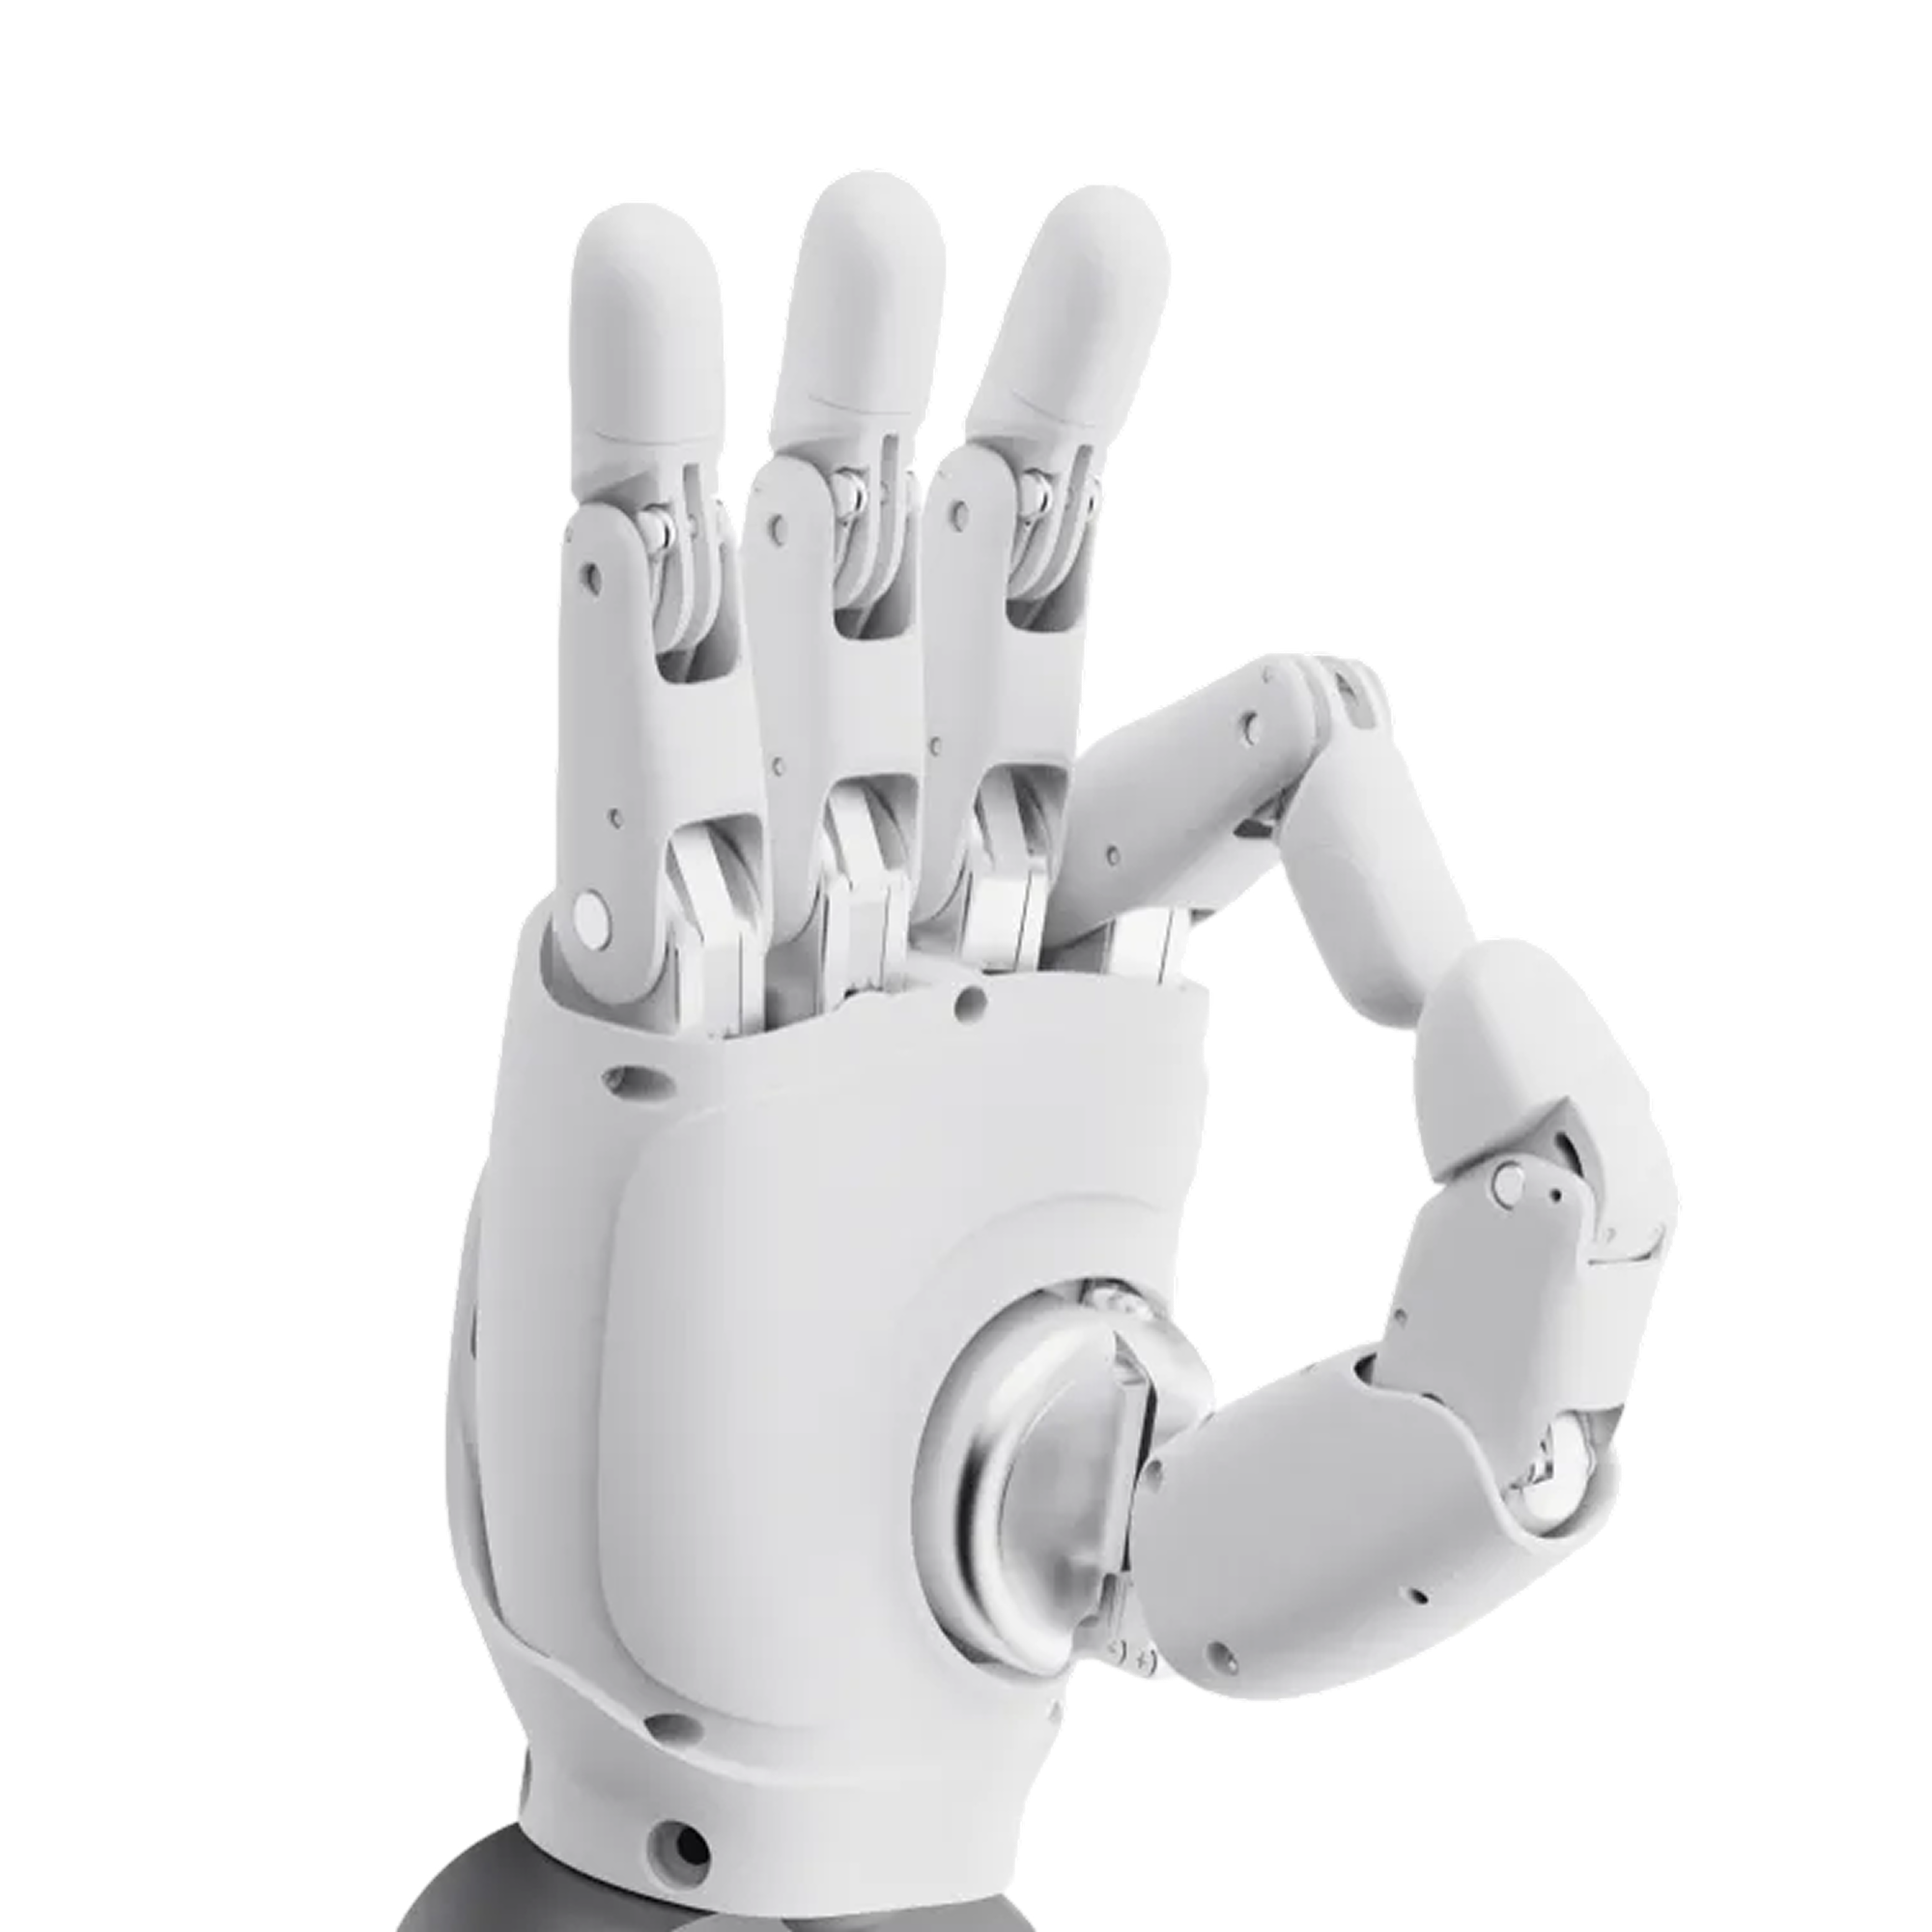


Compact high-DoF interactive dexterous hand with small form factor and total compatibility.
As the industry's only compact, high-DoF dexterous hand, OmniHand delivers universal compatibility across humanoid robots and greatly enhances interactive intelligence.
A compact hand for expressive gestures and safer human–robot interaction.
180 mm long and weighing up to 550 g, with a compact form designed for integration with humanoid robots.

16 total degrees of freedom enable expressive, human-like gestures. Back-of-hand touch sensing adds another way to interact.

Over 400 force-sensing taxels enable responsive force perception. An anti-pinch design supports safer human–robot interaction.


AGIBOT OmniHand 3
Answers on applications, robot compatibility, control and warranty.
The AGIBOT OmniHand is a compact, high-degree-of-freedom interactive dexterous hand primarily focused on interactive scenarios and light-duty tasks. These include:
・Interactive Services: Gesture interaction, rock-paper-scissors games, touch interaction.
・Light-duty Tasks: Gripping objects, delivering documents, etc.
・Research and Education: Mobile manipulation, scientific research and development.
Standardized interfaces (USB, RS485, CANFD) are provided, making it compatible with mainstream robotic arms and humanoid robots (such as AGIBOT's X2, A2, and other similar full-size or half-size humanoid robots). Customers can download and view the 3D model before purchase to conduct compatibility tests and ensure suitability before placing an order.
It supports multiple control methods:
・Manual Control: Operate via keyboard or upper computer commands.
・Intelligent Control: Compatible with ROS systems and Python programming, and can integrate with vision recognition (e.g., AI camera automatic positioning and grabbing).
・Teleoperation Control (Optional): Compatible with EMG sensors, teleoperation gloves, or exoskeleton devices, suitable for secondary development in teleoperation scenarios.
An instruction manual and SDK user guide are provided. Operators must have basic knowledge of robotics and should follow the user manual for compliant operation.
Weight: OmniHand 3 weighs approximately 0.55 kg.
Installation Dimensions: The base interface diameter is 58 mm, with a 10 mm operational clearance required. Customers can download and view the 3D model drawings to plan the device layout in advance.
It has passed ISO9001 quality certification, CE, RoHS, and EMC safety certifications, meeting the needs of daily use, research and education, and delivery services.
Self-Support: Resolve issues independently through technical documentation, development guides, and self-inspection.
Manual Support: Only hardware warranty is provided. Technical issues must be resolved by the user. Please carefully read and confirm the "Technical Capability Confirmation Agreement" before placing an order to ensure it aligns with your technical capabilities.
Emergency Issues: Power off immediately and contact after-sales support. Users are responsible for data security.
Warranty: 6-month warranty.
Not Covered: Damage caused by improper use, including short-circuit burnout, forced disassembly, or failure to follow the provided instructions.
EXPLORE FURTHER
Explore documents for OmniHand 3 and the related product family.
Browse OmniHand 3 resourcesNeed documentation for your configuration? Ask our team