
OPTIONAL
Fingertip tactile sensing
All five fingertips, including the inner sides of the index finger and thumb.
Shop by robot type
Product series
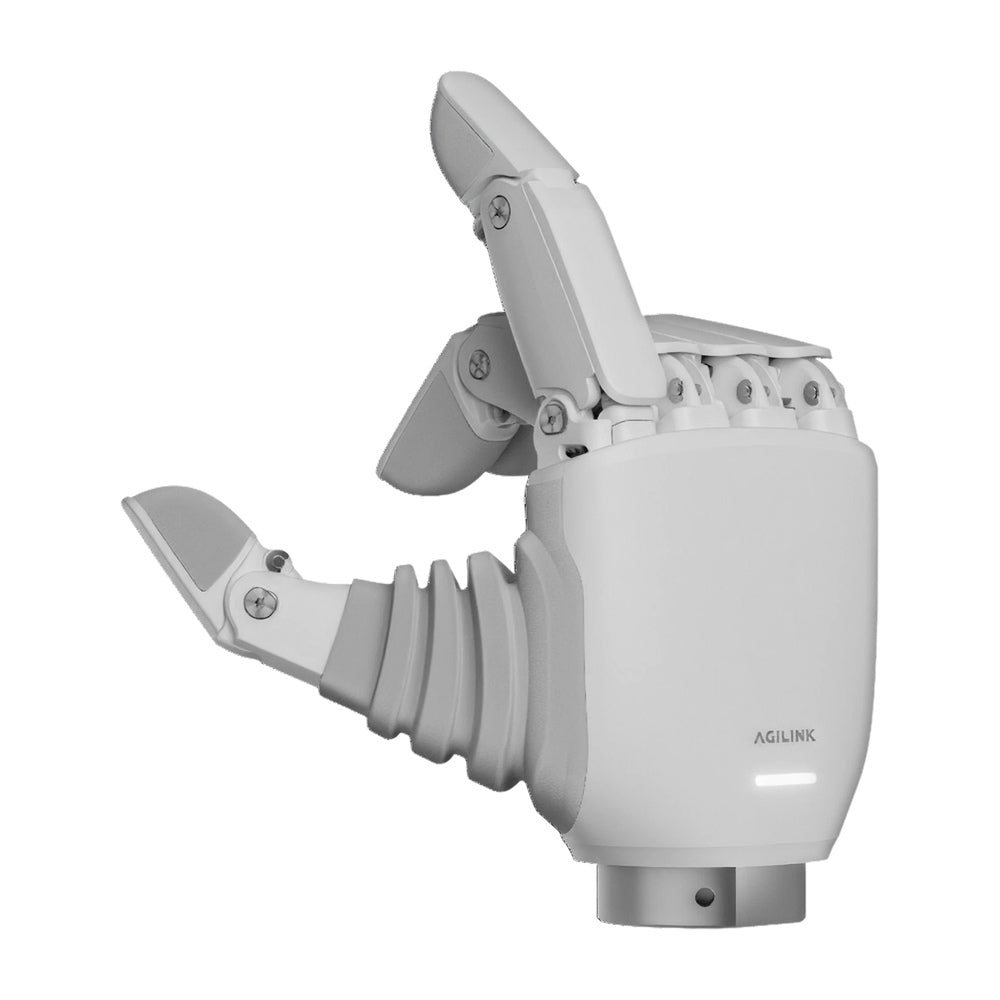


A compact, lightweight dexterous hand for smaller humanoid robots. With 4 active and 11 total degrees of freedom and a 0.5-second open / close time, OmniHand 3 Lite-S supports expressive interaction and everyday manipulation. The standard configuration is supplied without tactile sensors. Available as a left hand, right hand or a pair.

DEXTEROUS HAND · SMALL HUMANOID ROBOTS
Compact. Tough.
A small dexterous hand for expressive interaction and everyday manipulation.
NEW RELEASE · OmniHand 3 Lite · Small
SMALL, LIGHT, FAST AND TOUGH
Compact, lightweight, fast, tactile-ready, rich in gestures and ready for data collection. Dexterous interaction goes from a pricey add-on to an affordable standard.
Drop test reference: GB/T 2423.7—2018.
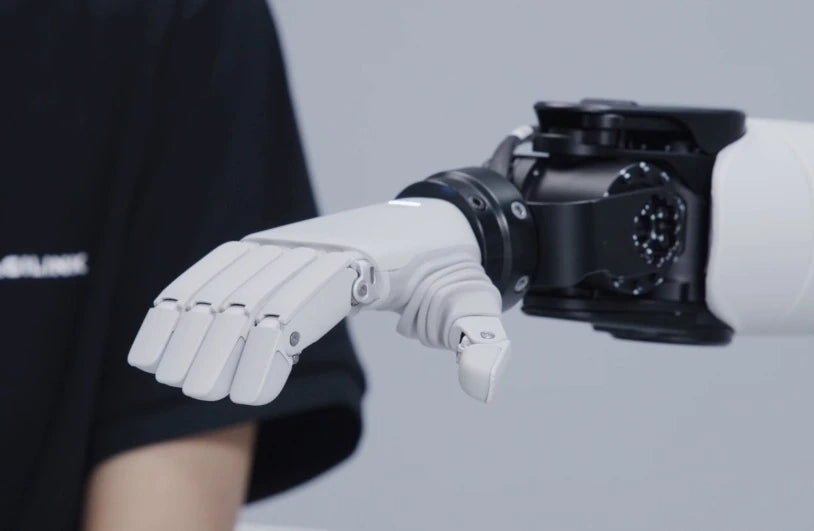
01 / COMPACT SIZE
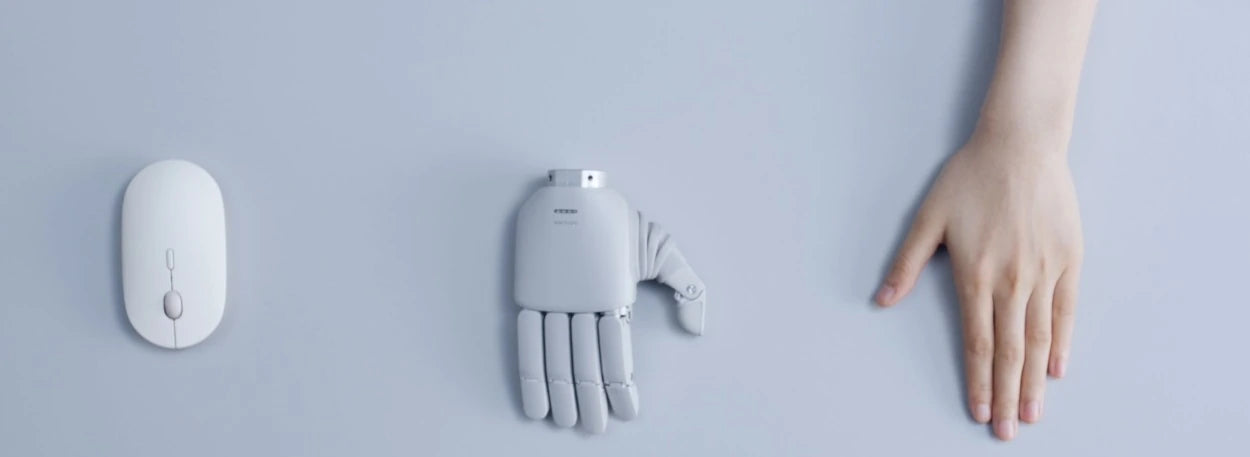
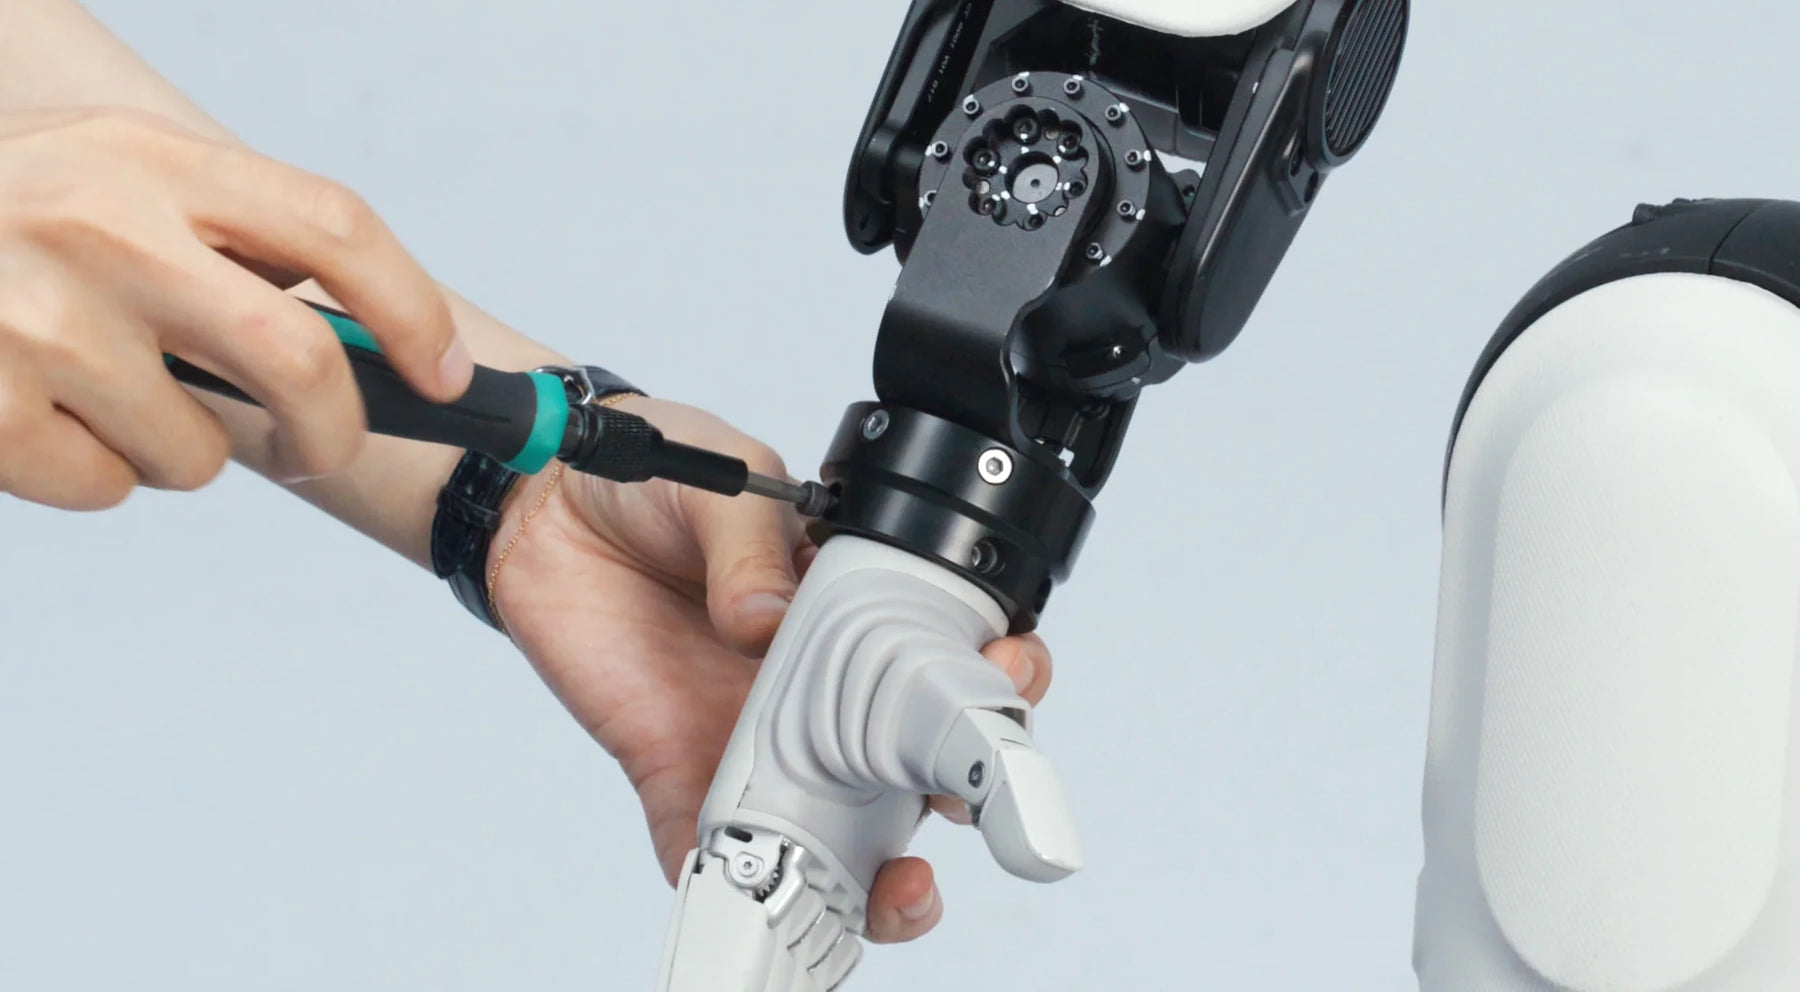
Small humanoid robots have limited wrist space and payload. Lite-S is designed for their proportions: quick to install and just the right size.
02 / LIGHTWEIGHT
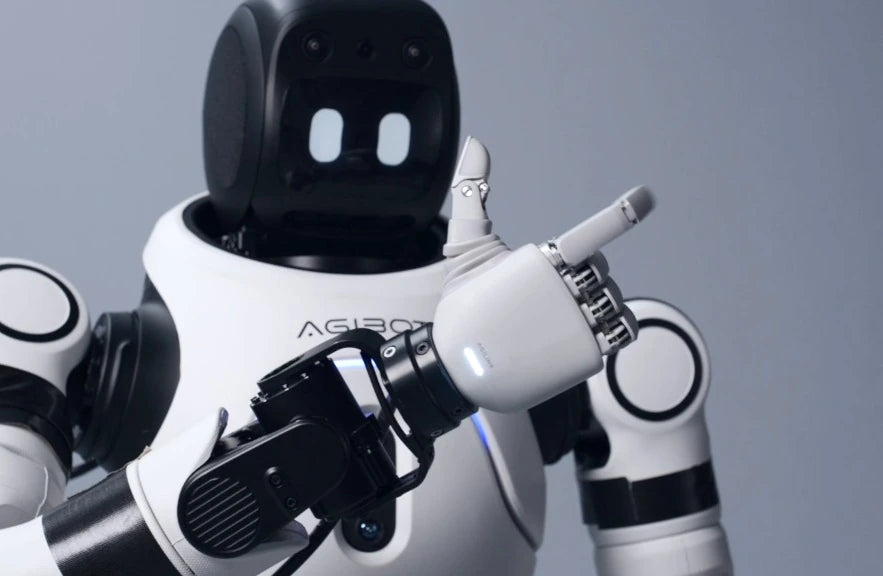
A lighter hand means lower arm inertia: smoother motion, lower energy use and less load on the arm.
≤350 g · hand weight
03 / FAST RESPONSE
A 0.5-second open / close time enables quick responses to interaction commands. Motion planning needs no extra buffer time, keeping each sequence fluid.
0.5 s · open / close time
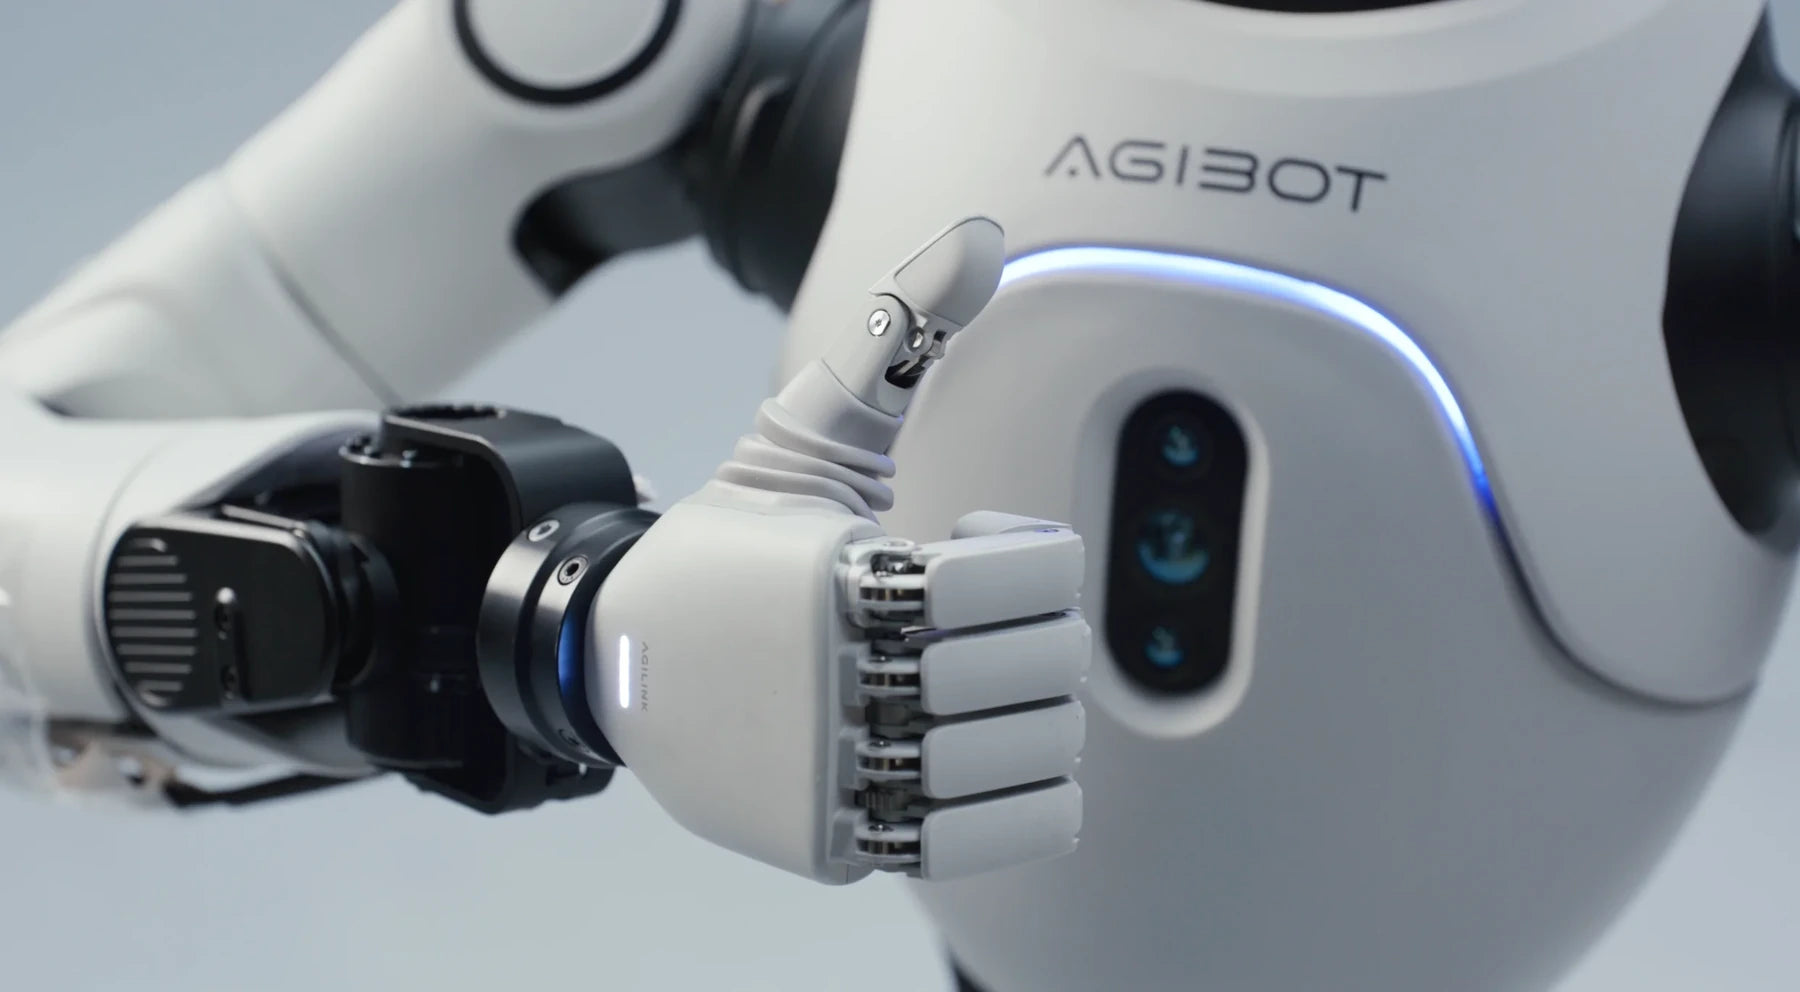
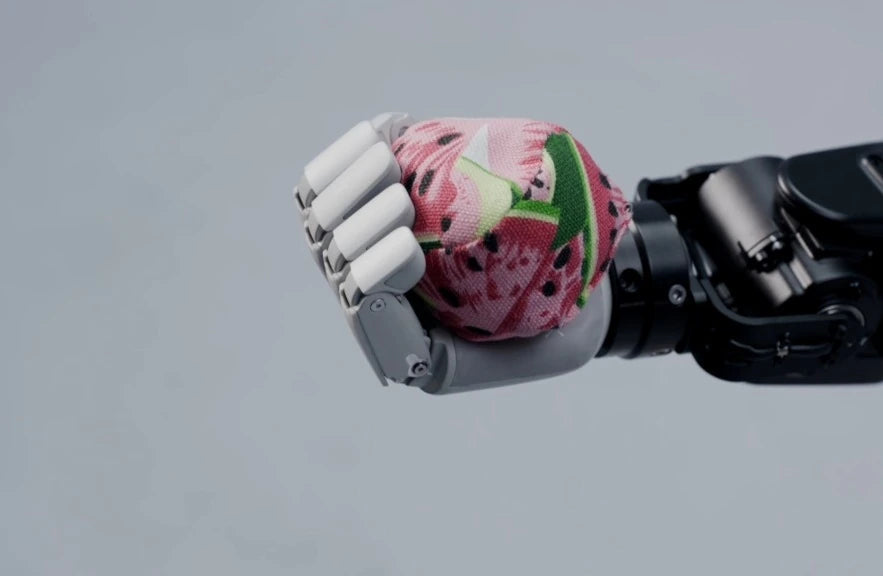
04 / 11 DEGREES OF FREEDOM
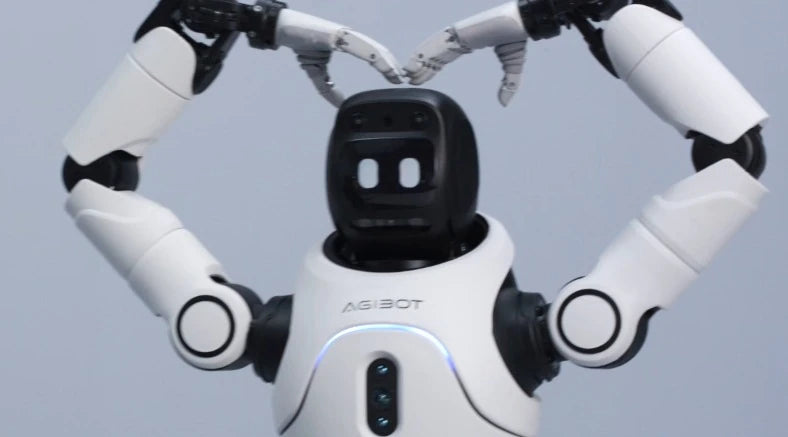
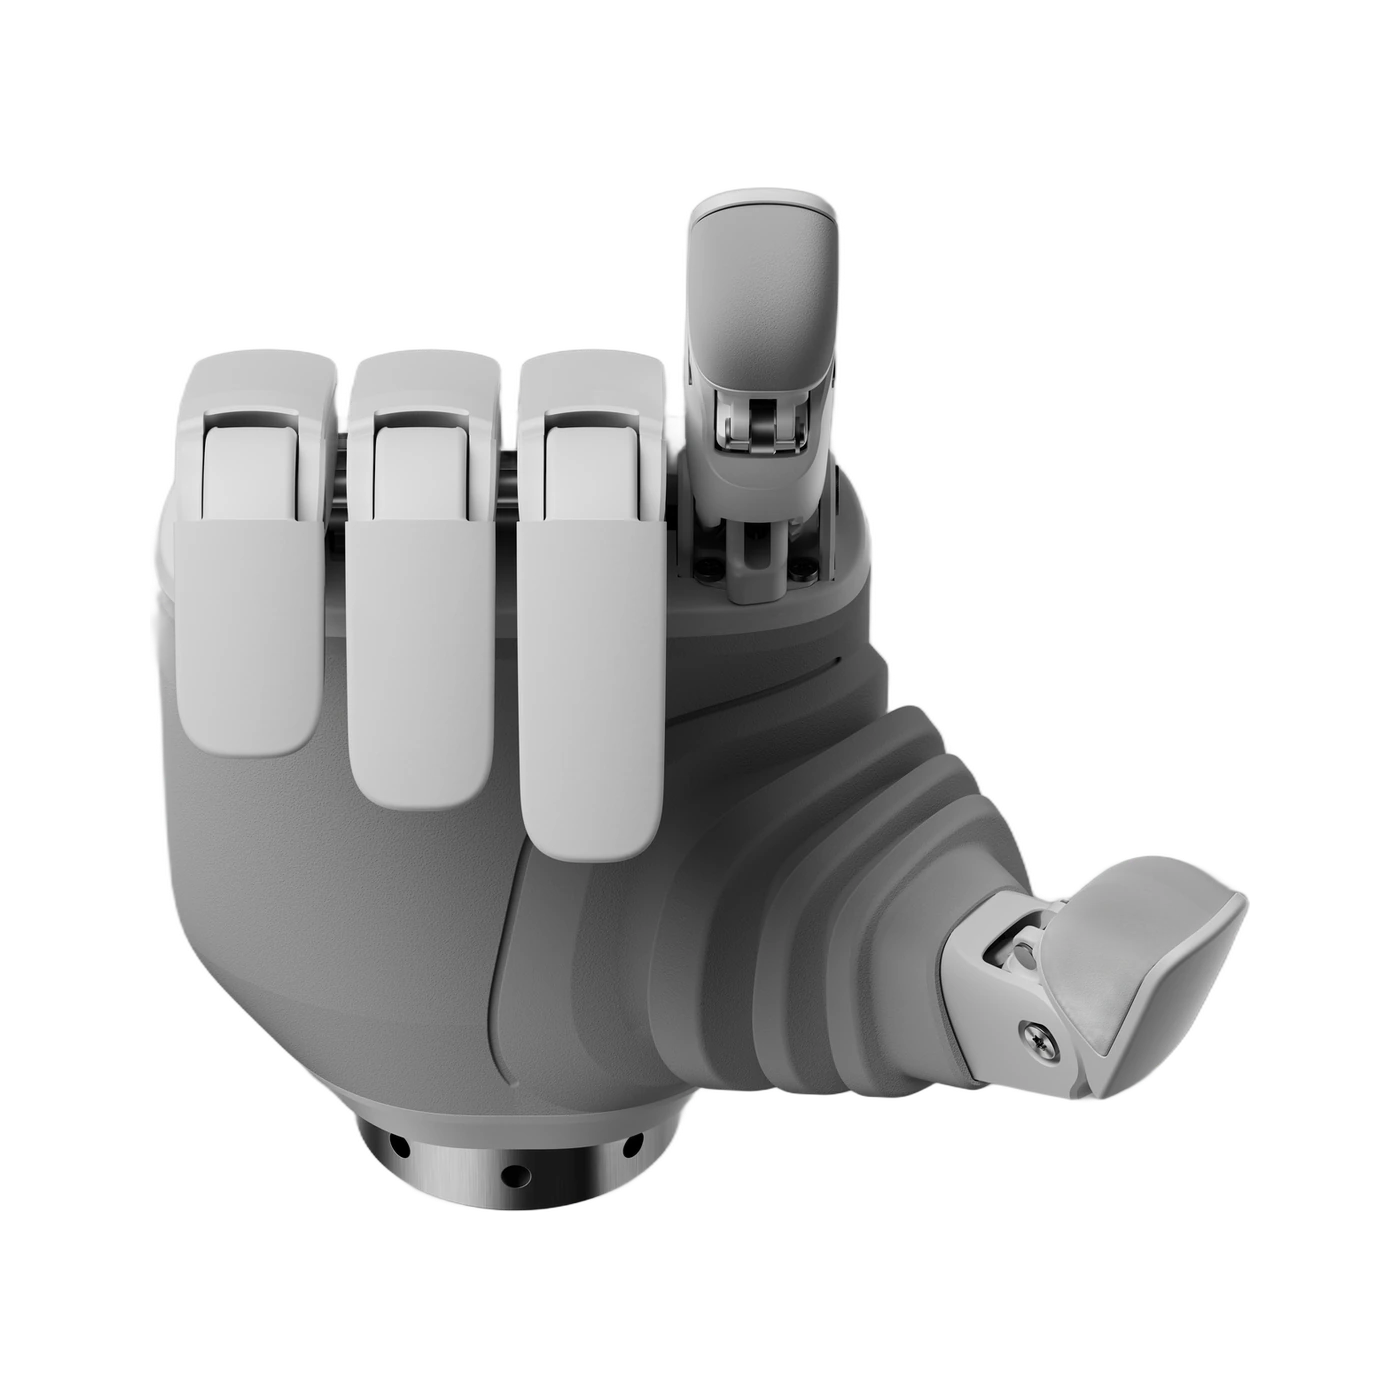
Four active DoF drive 11 joints: two for the thumb, one for the index finger and one shared by the middle, ring and little fingers. This arrangement enables natural-looking gestures for entertainment, performances and human–robot interaction.
05 / RUGGED BUILD
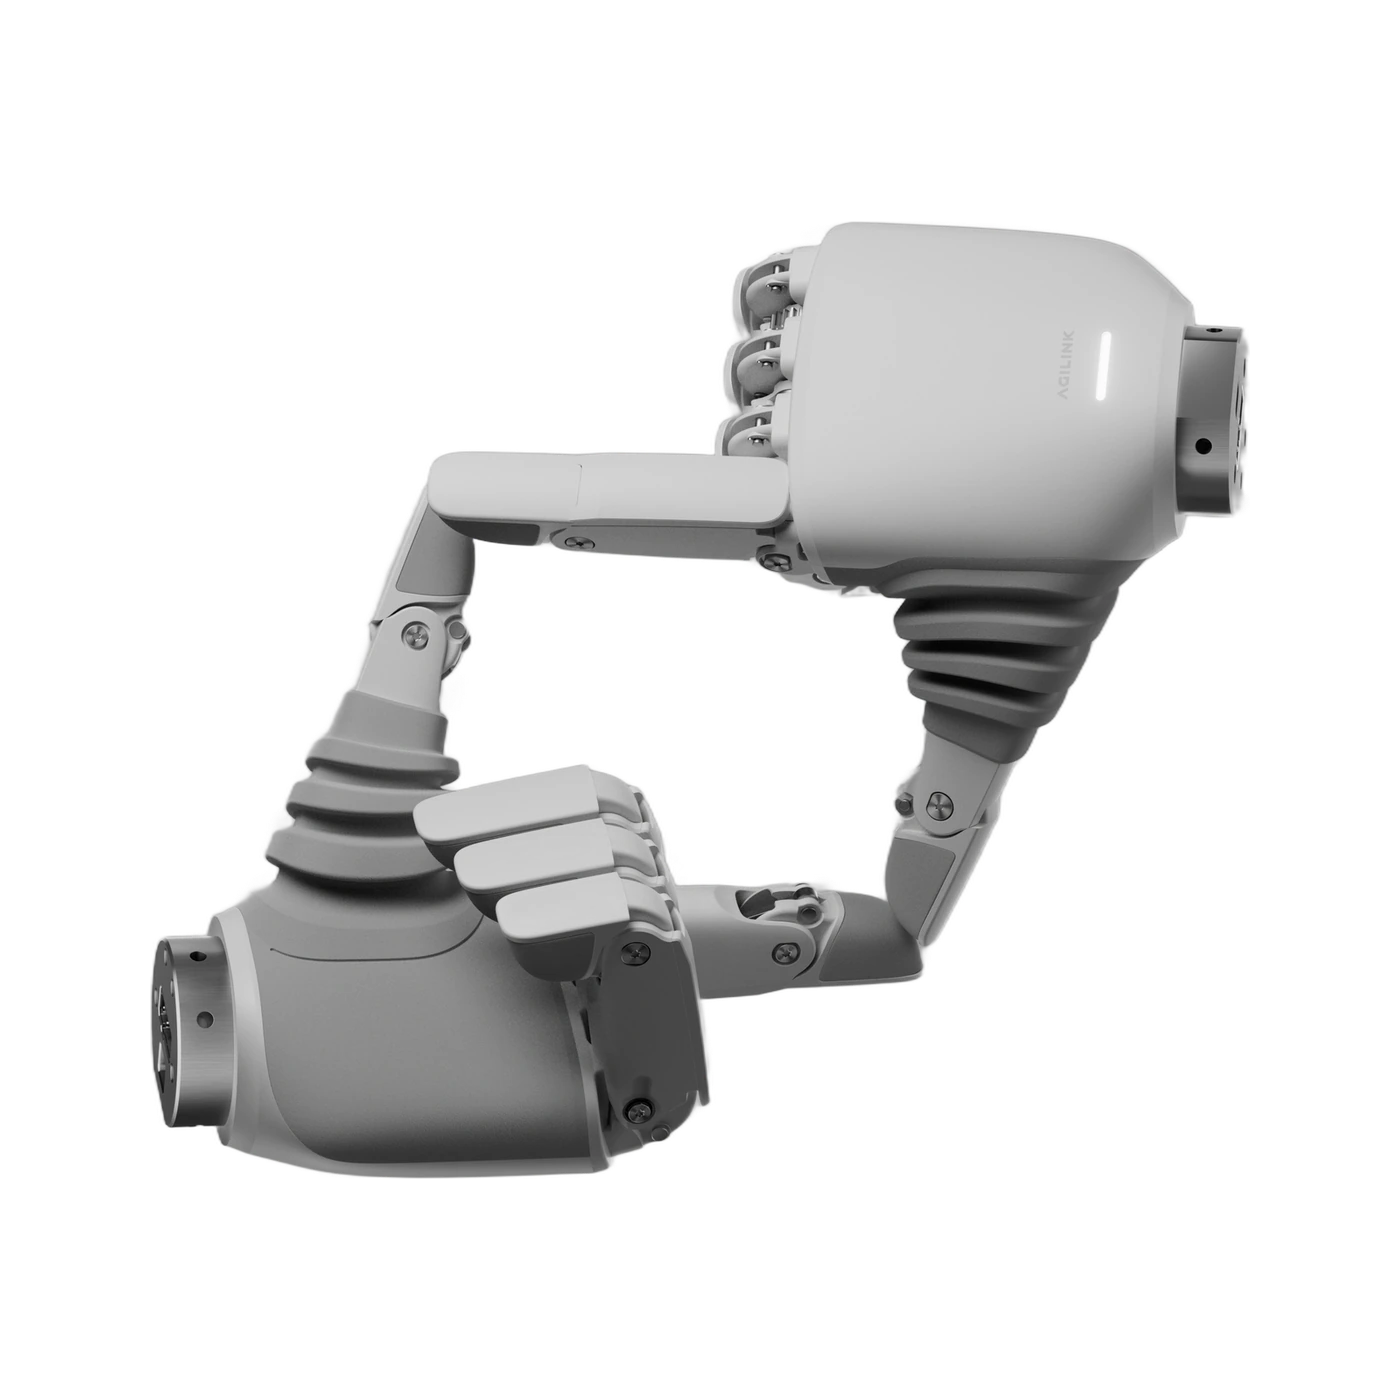
An aerospace-grade alloy frame keeps the hand light and structurally strong. When a robot falls or scrapes against a surface, the hand stays reliable, helping reduce repair and replacement costs.
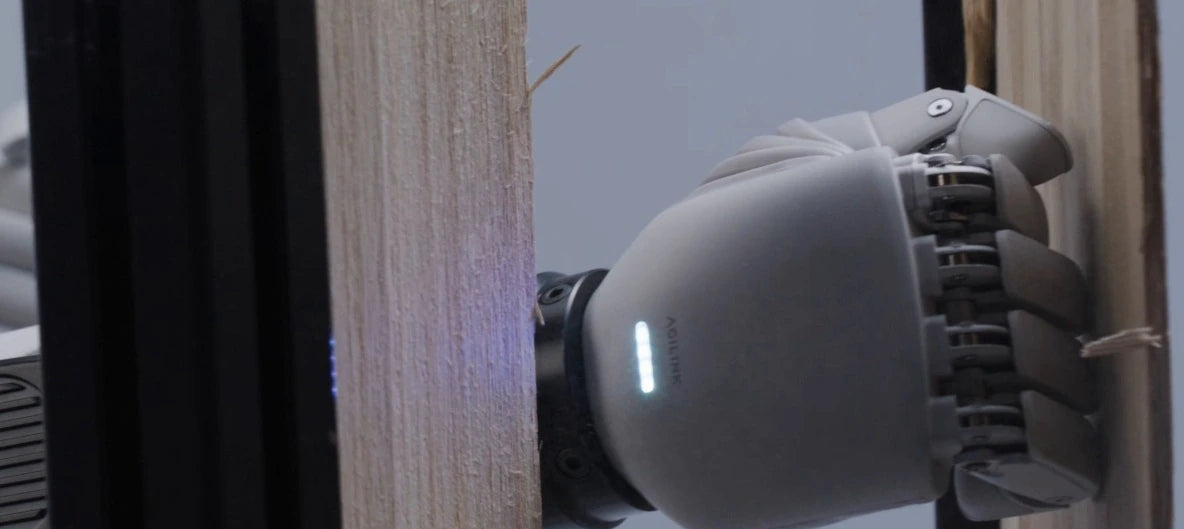
1 m · free-fall drop
Per GB/T 2423.7—2018, AGILINK reports five drops from 1 m on each of the hand’s six sides, with no loss of function.
06 / SAFE INTERACTION
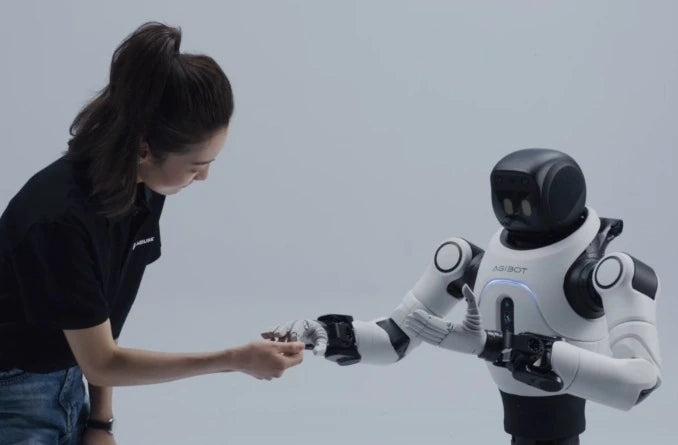
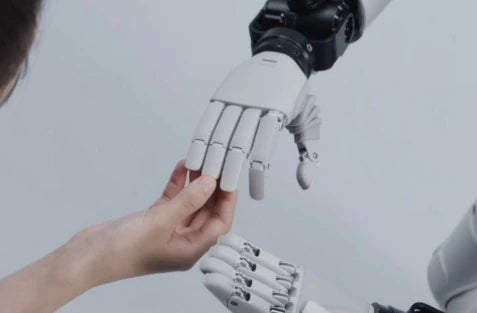
Handshakes, fist bumps and hand-offs feel safer for people. The durable soft cover can be replaced independently.

07 / TACTILE · OPEN ECOSYSTEM
Add fingertip and palm tactile sensing for contact feedback and data collection. Open SDKs, control interfaces and low-level protocols give developers room to build.
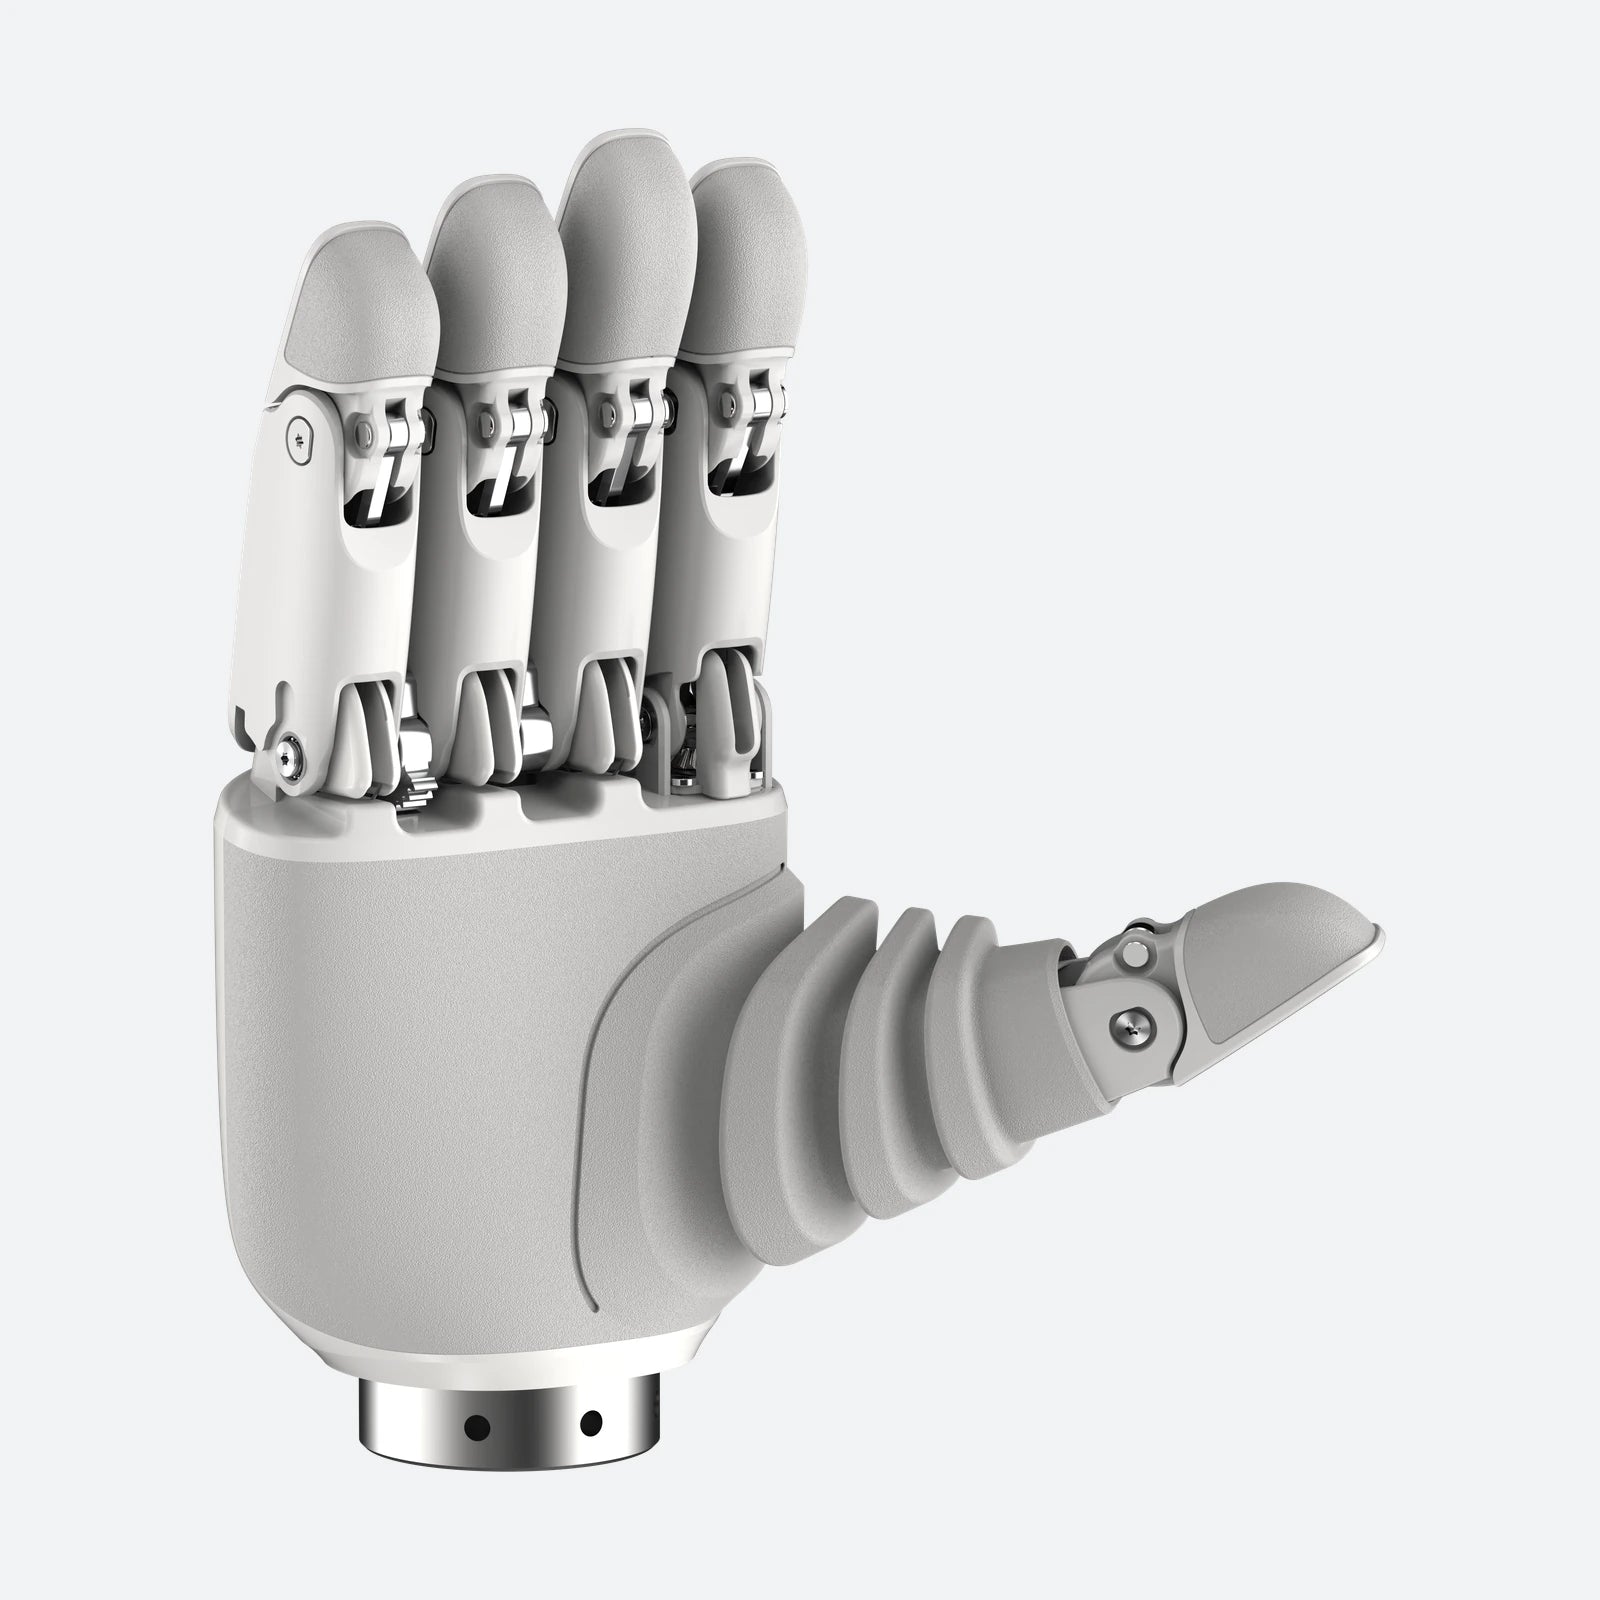
Fingertip and palm sensing available on the optional version.
OPTIONAL
All five fingertips, including the inner sides of the index finger and thumb.
OPTIONAL
Contact feedback from the palm surface.
FULLY OPEN
CAN FD / RS485 communication. Position, force–position hybrid and force–position–velocity hybrid control.
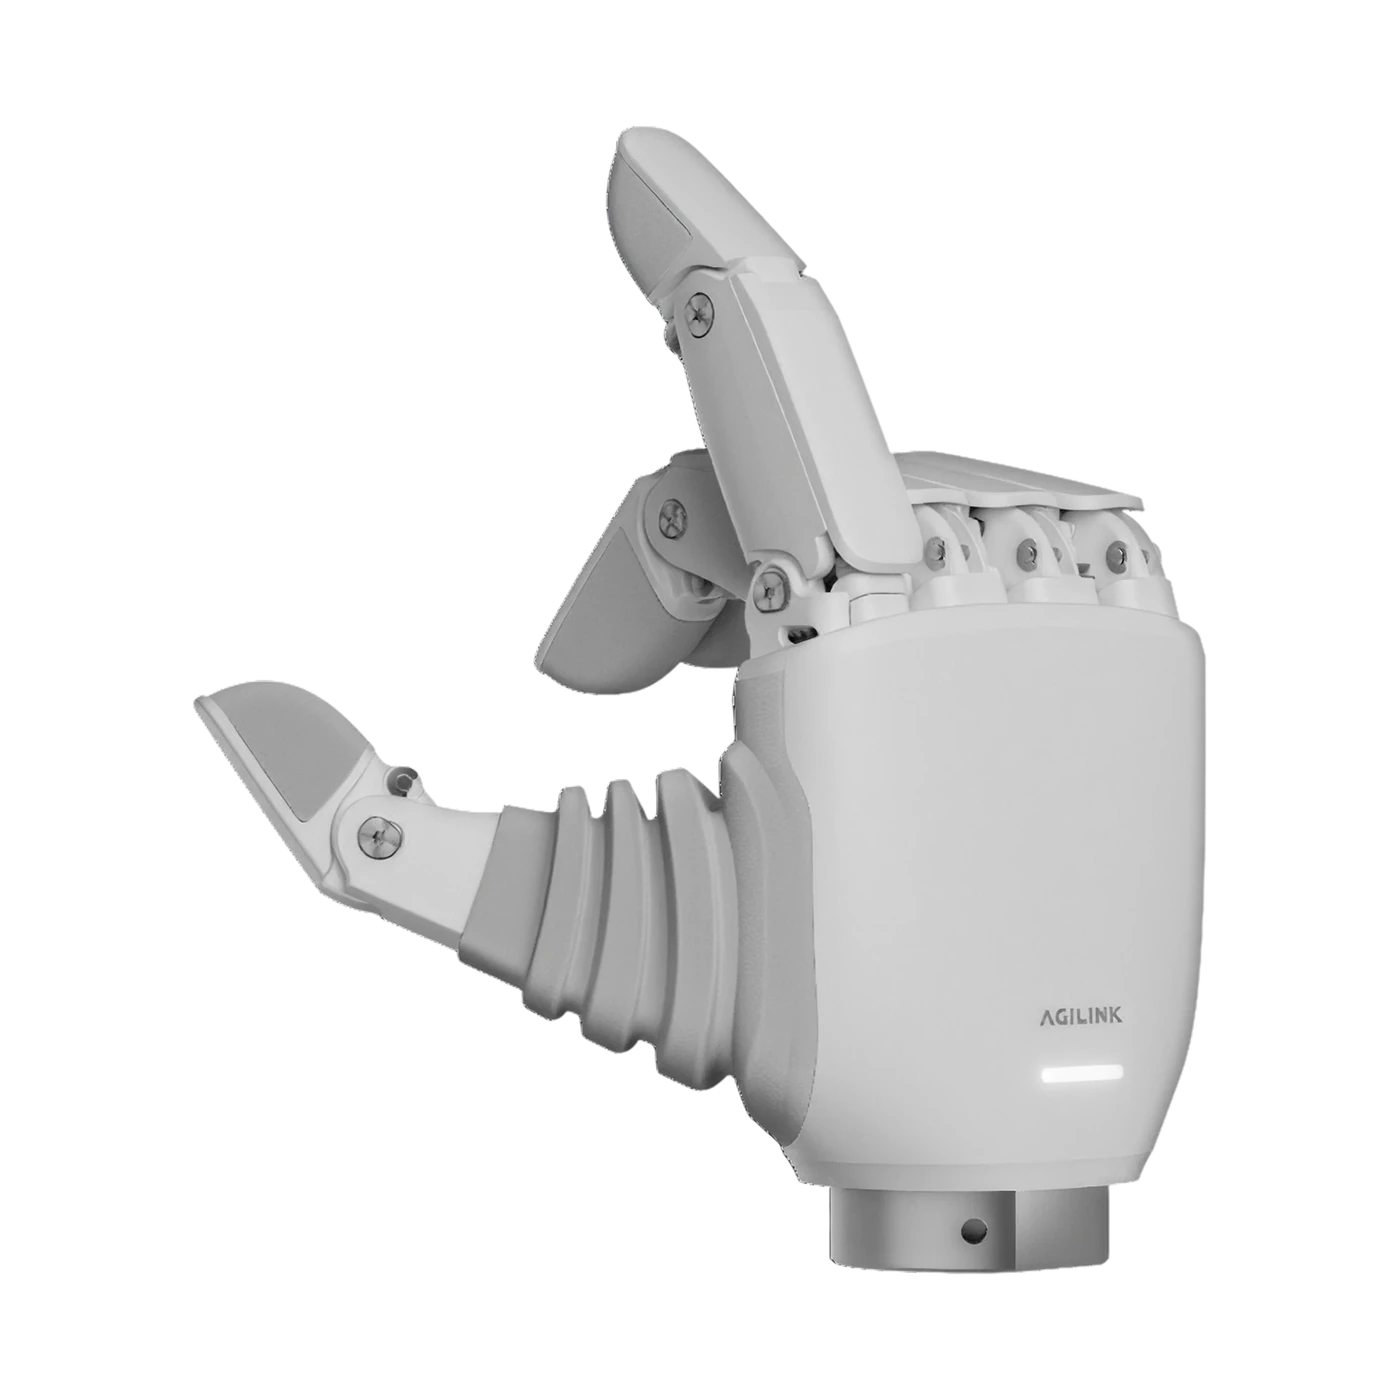
Develop expressive interaction.
08 / DAILY TASKS
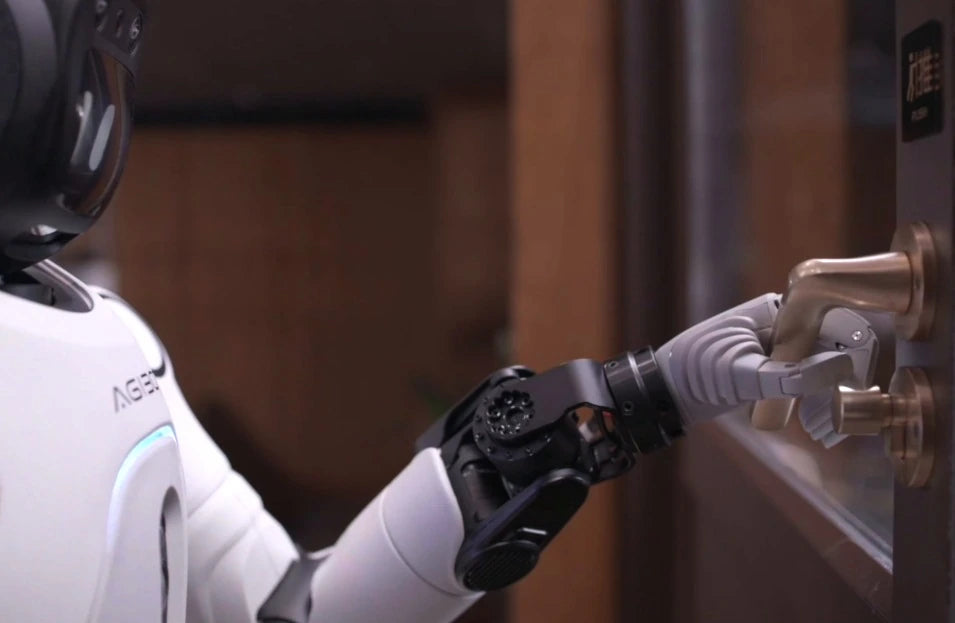
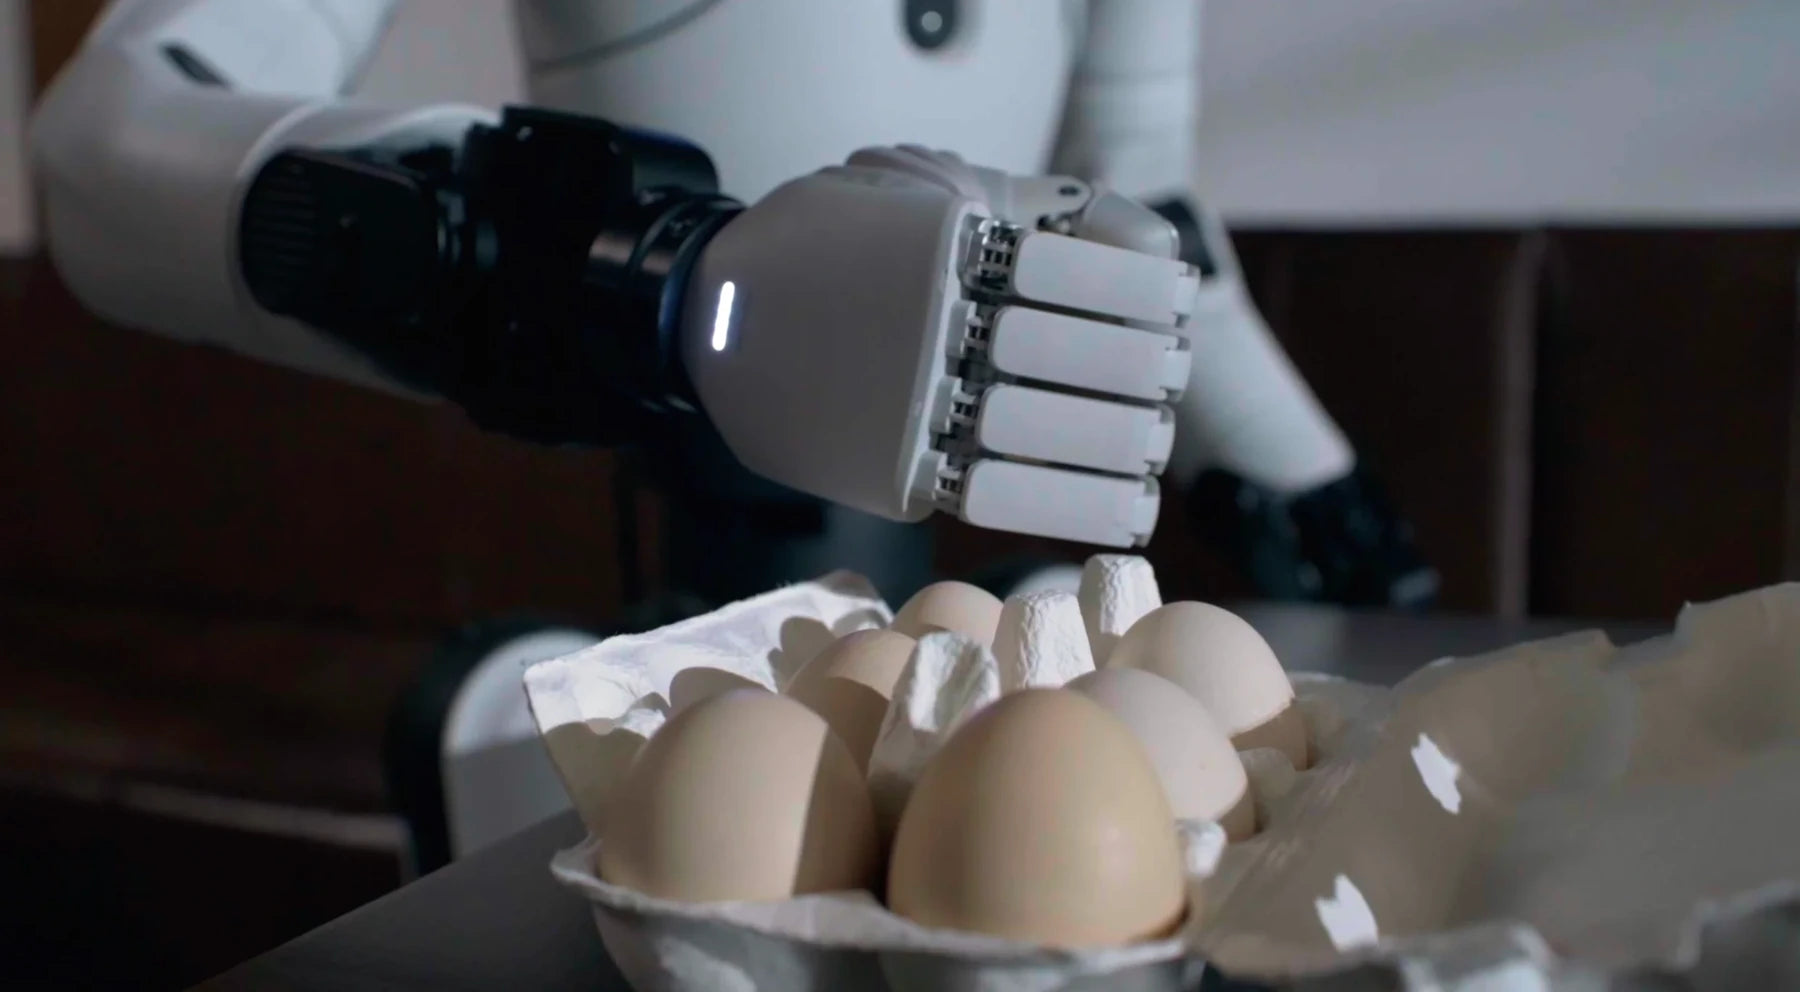
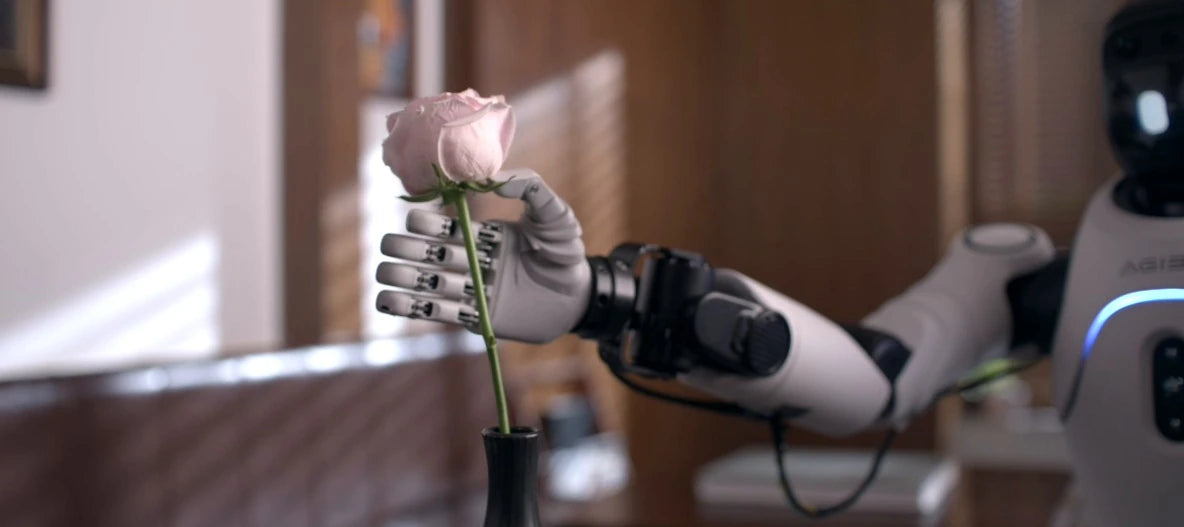
Carry trays, pick up cups, hold props and hand over items. Every move is yours to define.
09 / CHOOSE YOUR CONFIGURATION
Choose the standard hand or the configuration with tactile sensors. Both versions are available as a left hand, right hand or a pair.
The standard hand, supplied without optional tactile sensors.
View standardThe sensor-equipped configuration for tactile feedback.
View tactile version“Both hands” includes one left hand and one right hand. Choose a configuration, then select Left, Right or Both hands in that product’s options.
SPECIFICATIONS
Single-hand specifications from AGILINK’s English product material. Optional tactile sensing applies to the sensor-equipped configuration.

EASIER · BETTER FIT · TOUGHER
Making dexterous interaction standard on every robot.
Open SDK · CAN FD / RS485
OmniHand 3 Lite-S
Discuss your applicationEXPLORE FURTHER
Explore documents for OmniHand 3 Lite and the related product family.
Browse OmniHand 3 Lite resourcesNeed documentation for your configuration? Ask our team